Automated RivetingWorkcell Integration
Mechanical integration, conveyance and twin robot packaging were developed around the OEM’s existing process modules to create a complete production workcell.
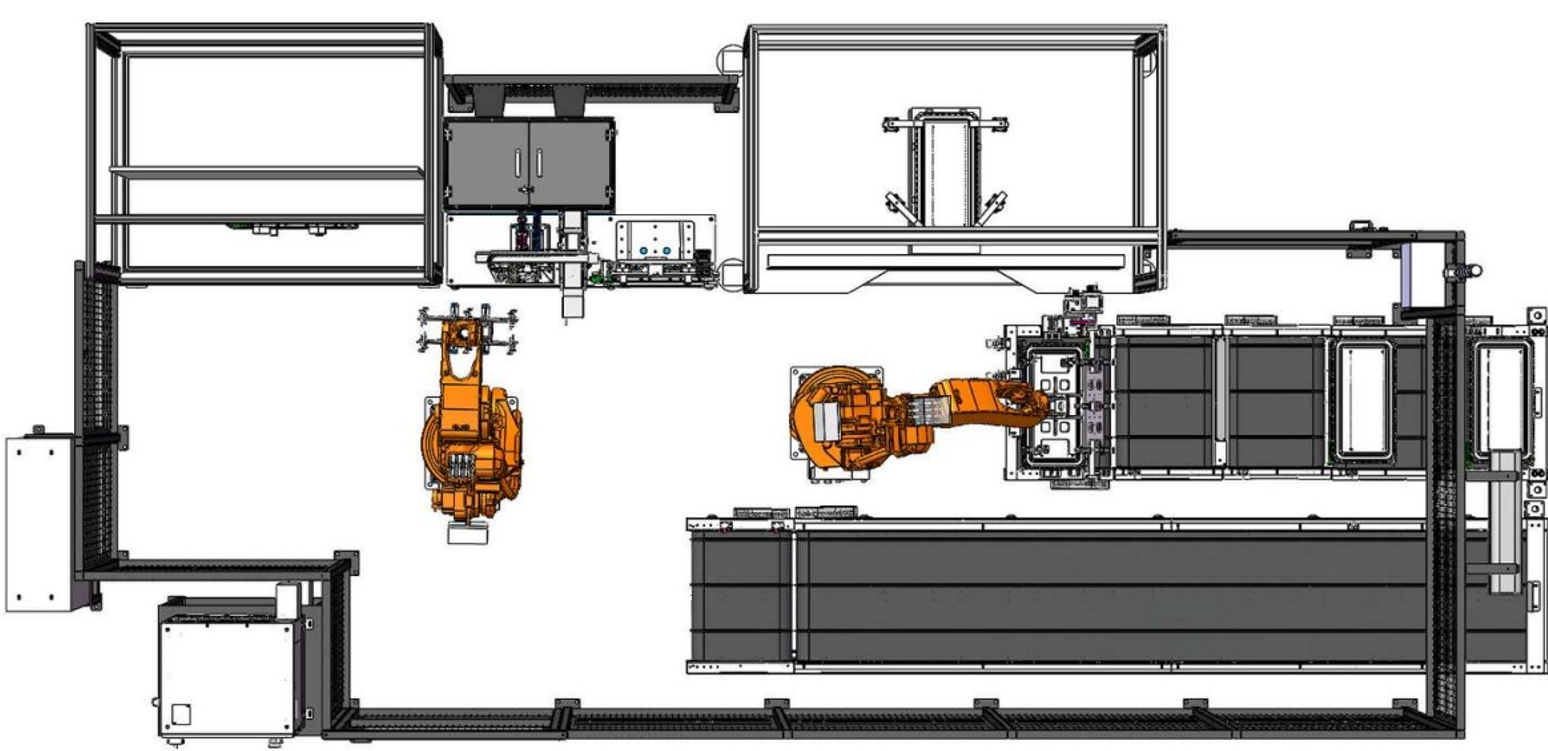
Build the cell around proven process equipment
The riveting, inspection and hole making equipment already existed as OEM process technology. Fabrixon had to integrate those modules with robots, conveyance, guarding and supporting structure without changing the process equipment itself.
- Process ownership
- OEM process modules remained unchanged.
- Integration risk
- Robot reach, service access, guarding and conveyor clearances had to coexist.
- Controls boundary
- Fabrixon defined the mechanical and electrical interfaces; the OEM retained programming and commissioning.
Resolve reach and interference before the frame is built
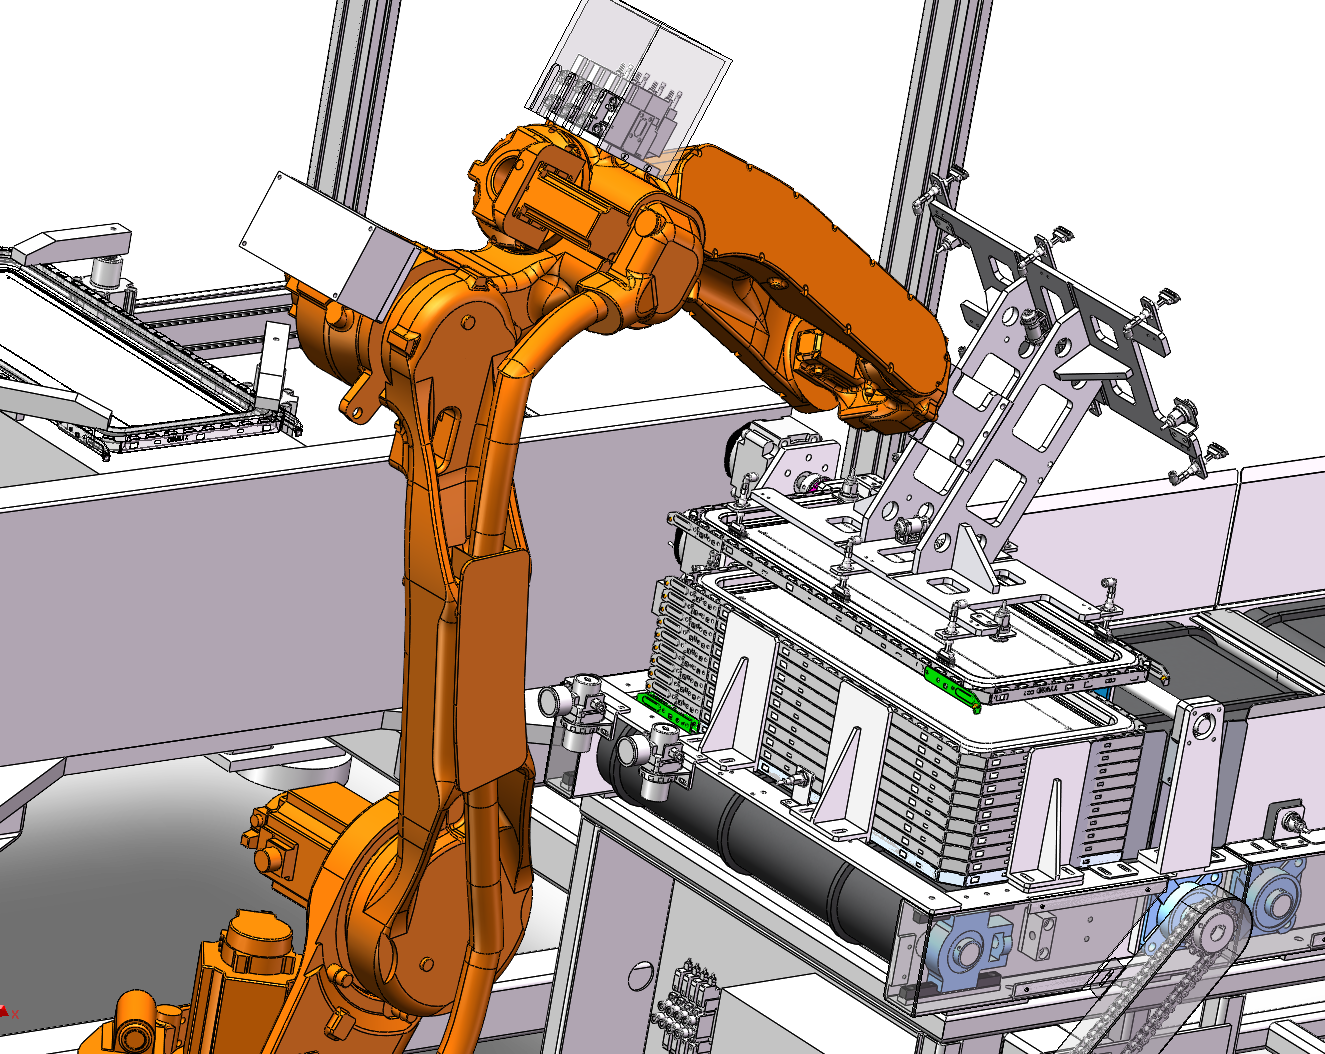
Robot models, mounting bases and end effector geometry were checked against the workcell envelope in CAD. The study identified mounting adjustments before fabrication, avoiding clearance problems during commissioning.
- Reach
- Required process points remained inside the usable robot envelope.
- Clearance
- Robot motion was checked against stations, conveyors, enclosure and the second robot.
- Mounting
- Base positions were adjusted in CAD where the proposed location created interference.
Carry the workpiece through the same controlled cell envelope
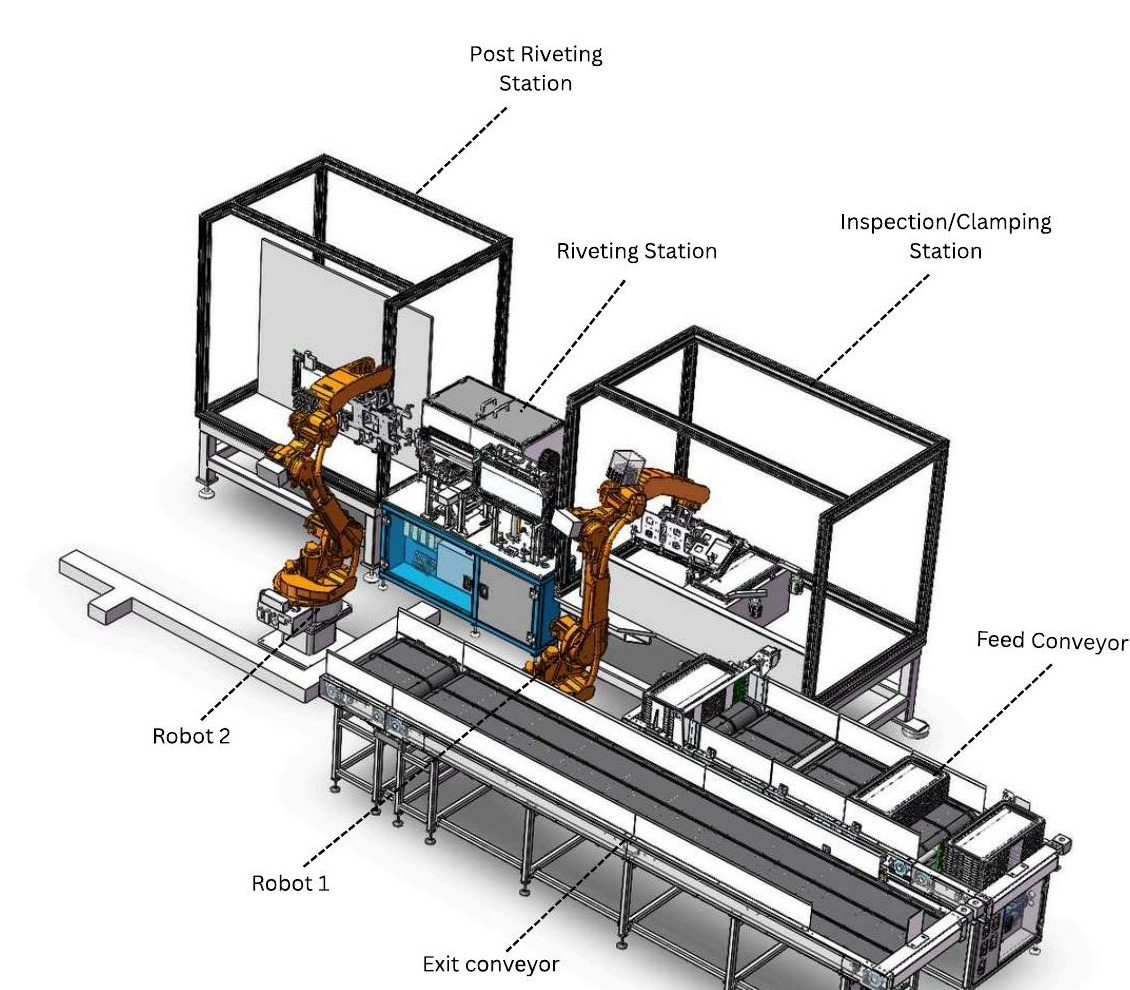
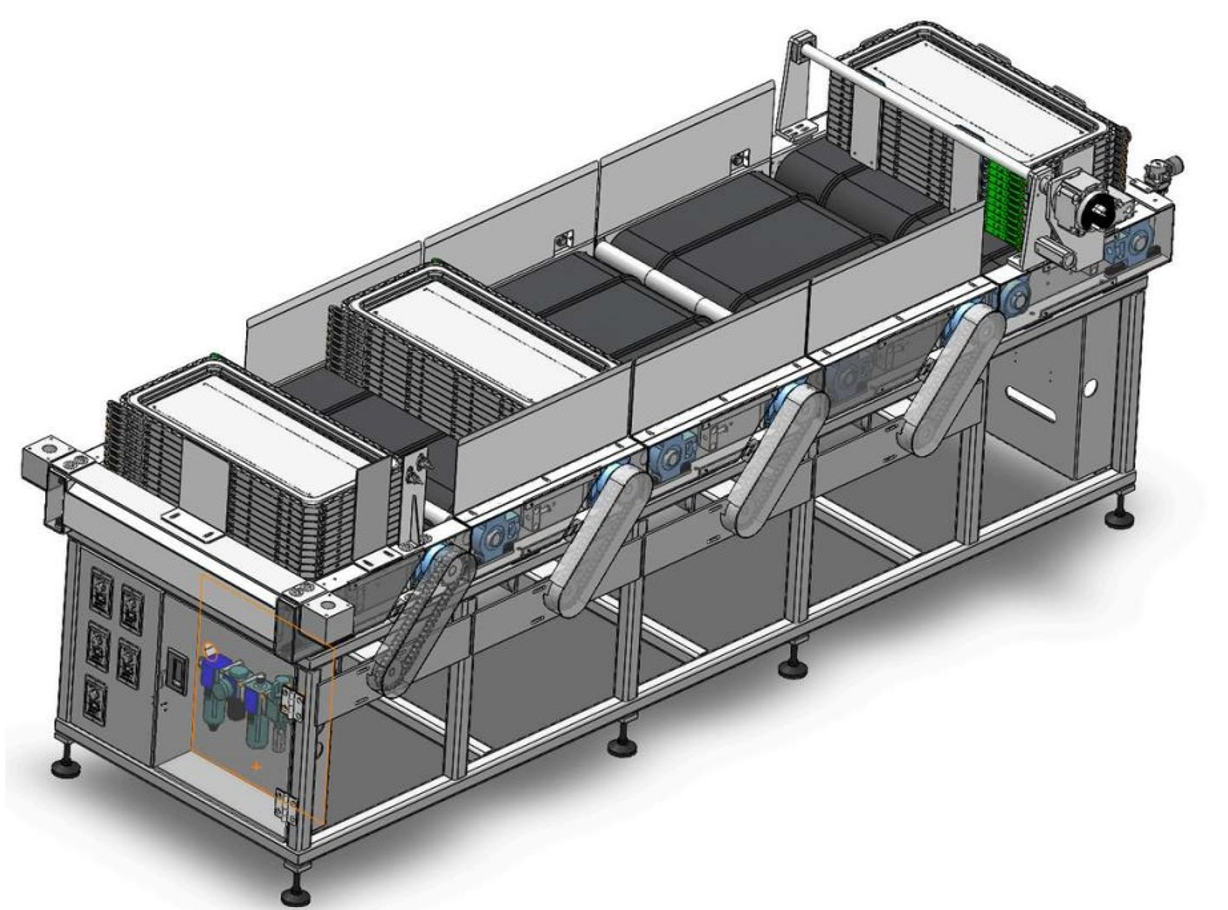
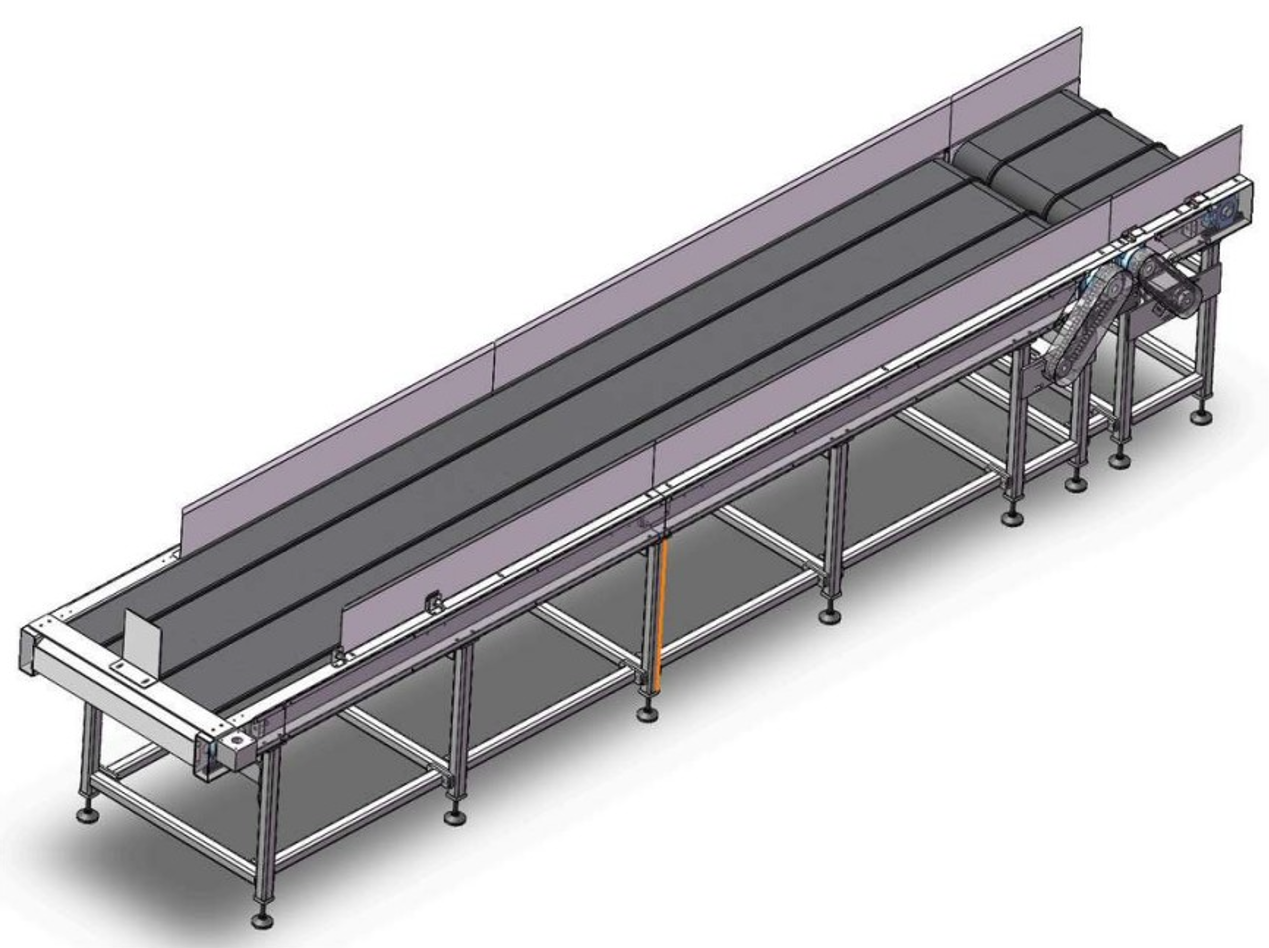
Feed and exit conveyors were developed as part of the workcell rather than treated as external add ons. Their supports, drive positions and workpiece presentation geometry were coordinated with the robot stations.
Give every module a defined mechanical boundary
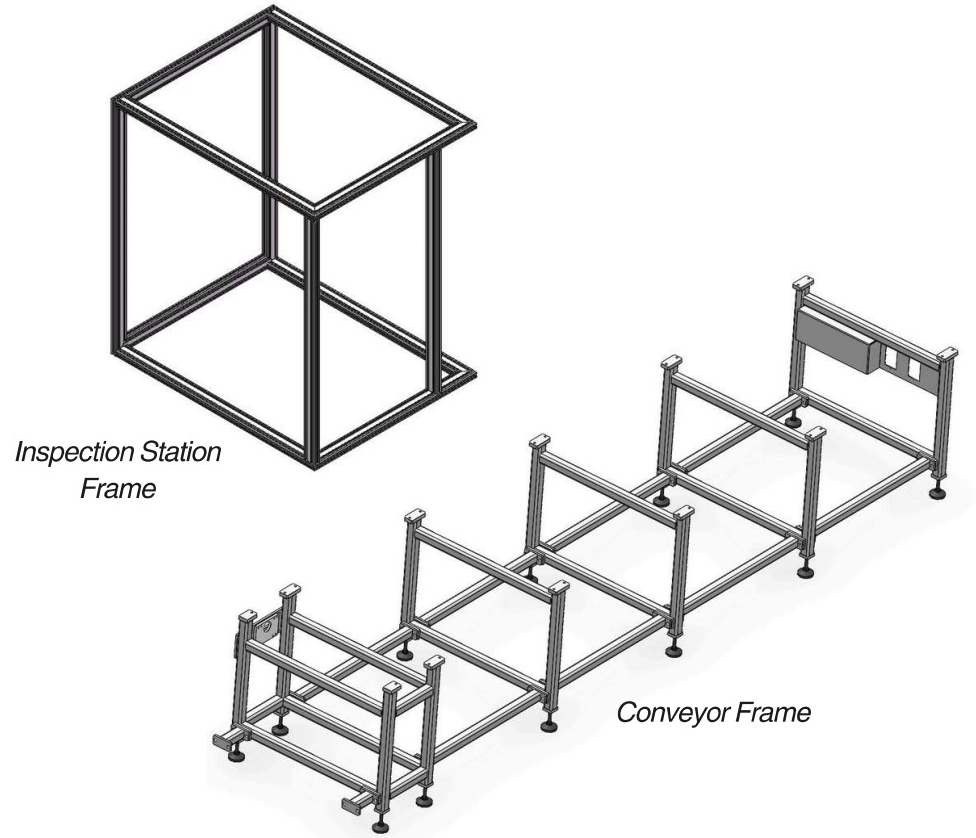
Process modules, robot bases, conveyors and perimeter guarding were tied to a common structural package. Service access, utility entry and safety device mounting were resolved before release.
- Structure
- Fabricated frames carried enclosure and equipment interfaces.
- Safety hardware
- Guarding, access points and sensing device mounts were mechanically integrated.
- Serviceability
- Maintenance access and module withdrawal space were retained around the cell.
One mechanical package for fabrication and controls
The released package defined module mountings, sensors, cable routes, access and robot interfaces, with Fabrixon remaining available through fabrication and commissioning.
- Fabrixon scope
- Workcell structure, conveyors, robot integration, guarding and mechanical electrical interfaces.
- OEM scope
- Process equipment, PLC and robot programming, panel build and physical commissioning.
- Handover
- The cell was built, commissioned and transferred into production.
The workcell succeeded because the interfaces were resolved before fabrication
Robot reach, process access, conveyance and guarding were treated as one mechanical problem rather than separate supplier packages.
An integrated workcell that entered production
The mechanical and integration package was released on schedule. The workcell was built, the OEM process modules were integrated, the robots were commissioned and the cell is operational.
- Robot integration
- Reach and clearance were validated before fabrication.
- Mechanical delivery
- Cell structure, conveyance and safety interfaces were released as one package.
- Production result
- The completed workcell was commissioned and handed over to production.